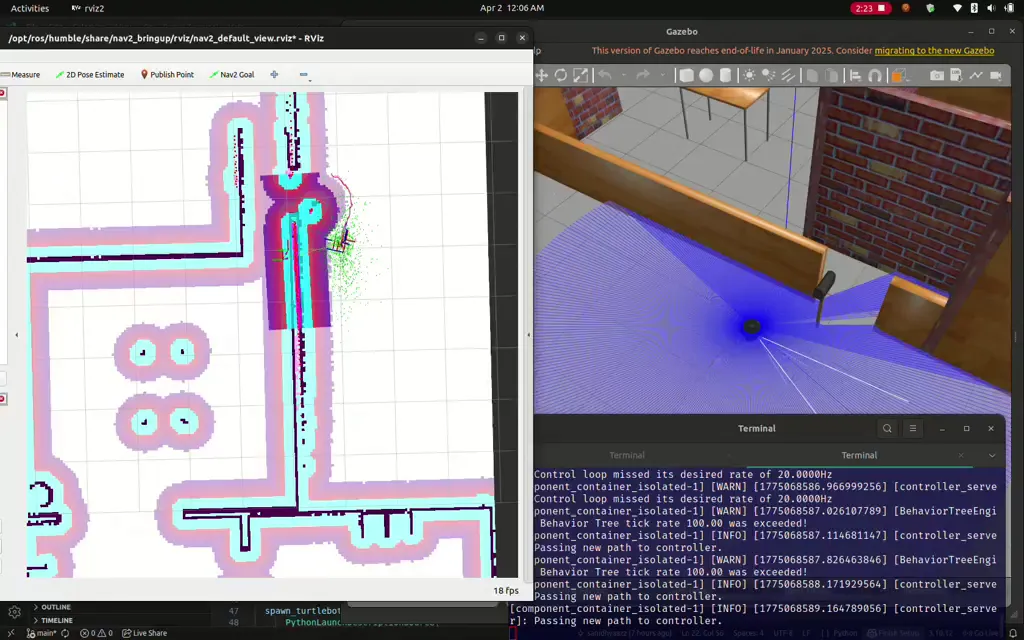
This project involves the development of an autonomous four-wheel holonomic mobile robot using ROS 2 and Nav2 for industrial material handling applications. The robot is capable of localizing itself, planning collision-free paths, and navigating autonomously while avoiding obstacles in real time. The system integrates localization, motion control, and embedded communication, and is validated using Gazebo and RViz.
Architecture
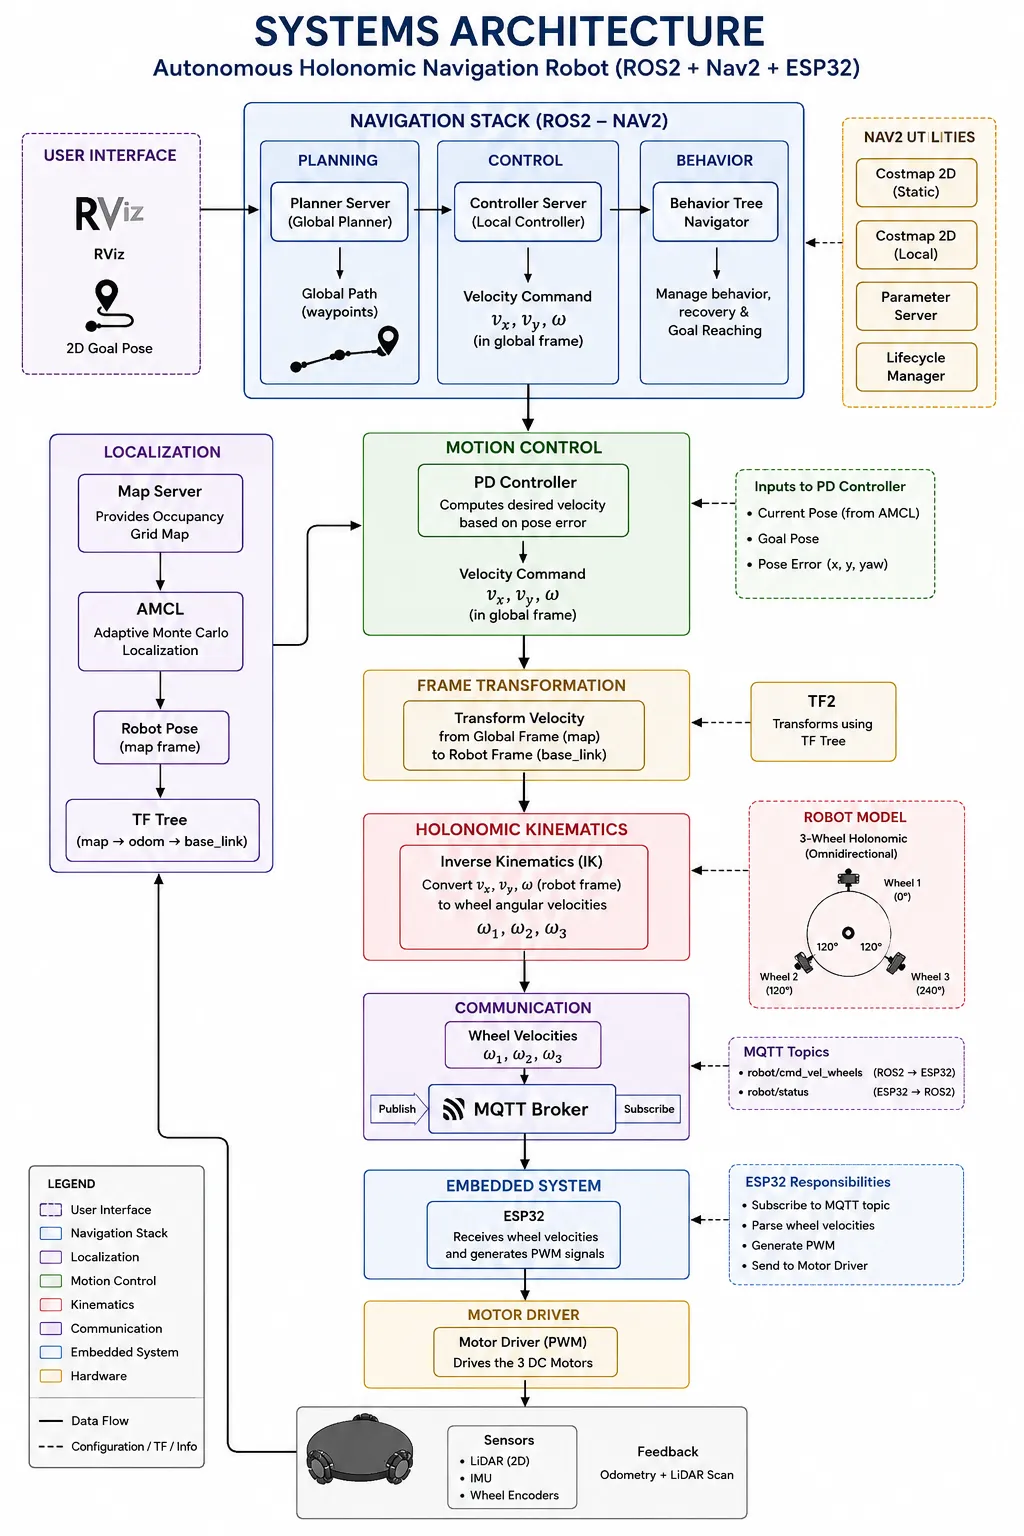
Designed and developing a four-wheel holonomic AMR for industrial material handling, enabling the transportation of goods between multiple locations in warehouses and manufacturing facilities. Built using ROS2 and Nav2, the robot autonomously localizes itself, plans collision free paths, and navigates to user-defined destinations. The system integrates AMCL for localization, TF2 for coordinate transformations, a PD controller with holonomic inverse kinematics for motion control, and MQTT communication with an ESP32 for real-time motor control. The complete navigation system was developed and validated using Gazebo and RViz.
What I Learned
- Implemented a complete
ROS2Nav2based autonomous navigation system for industrial AMRs. - Implemented localization using
AMCL, coordinate transformations usingTF2, and holonomic motion control. - Designed and tuned a PD controller with holonomic inverse kinematics for precise navigation.
- Integrated
ESP32withROS2viaMQTTfor embedded motor control. - Gained practical experience in robotics software architecture, industrial autonomous navigation, embedded systems, and system integration.